Product overview
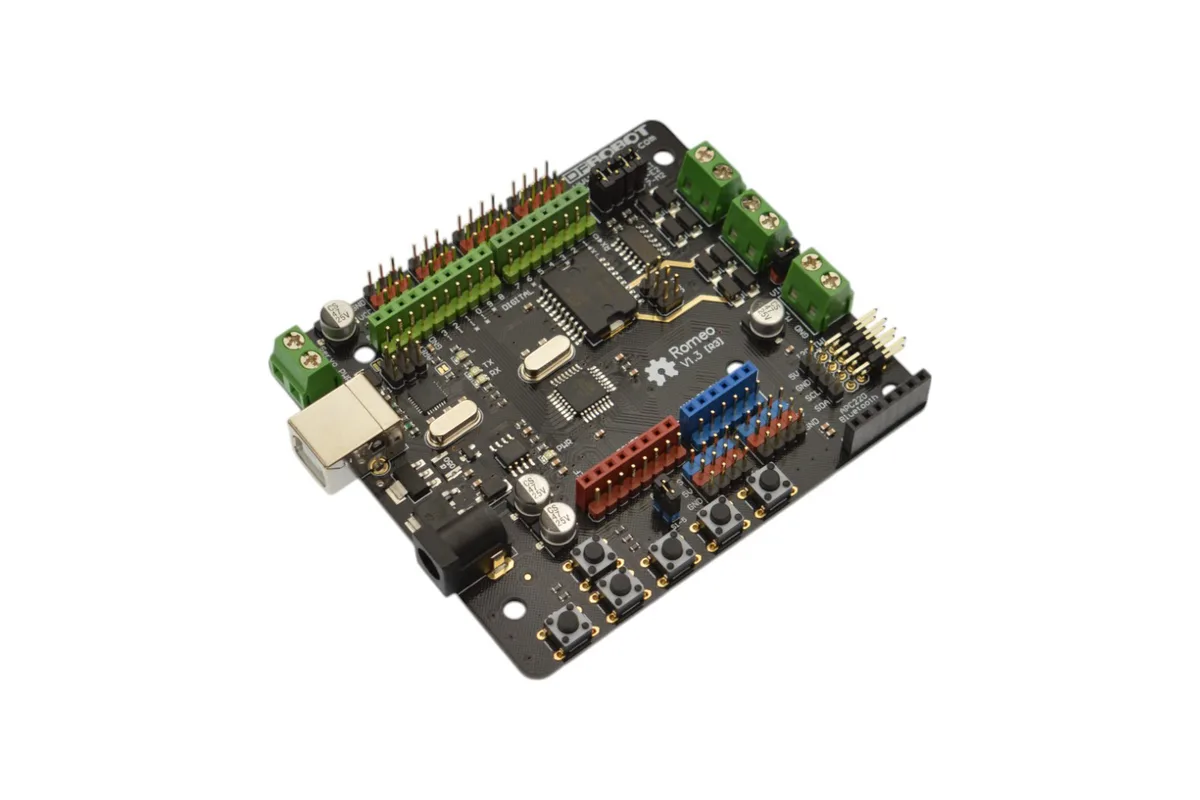
Romeo. The DFRobot Romeo is an all-in-one robot control board based on the Arduino Uno platform and built around an Atmega328 microcontroller.
Main characteristics. The integrated two-way DC motor driver supports a maximum current of 2 A, allowing two motors to be driven directly without an additional driver. The board provides 8 channels of 10-bit analog I/O and 5 key inputs.
Connectivity. The board includes integrated sockets for the APC220 RF module and the DF-Bluetooth module, three I2C interface pin sets, a TTL level serial interface, a USB interface and an ICSP header for direct program download. 3-pin connectors compatible with the Gravity series of sensors and actuators allow many sensors to be connected plug-and-play.
Power and environment. The board is powered by USB or an external 7 V to 12 V DC supply and provides 5 V / 3.3 V DC outputs as well as an external power output. An auto-sensing power input is integrated. Dimensions: 90 x 80 x 14 mm, weight: 60 g.
Typical uses. This board suits the construction of mobile robots, including those fitted with servos that need more current, thanks to its dedicated servo connector.
Integration. Compatible with the Arduino Uno pin mapping, the board can be extended with Arduino shields and programmed with the open source Arduino environment.