
ROB0143
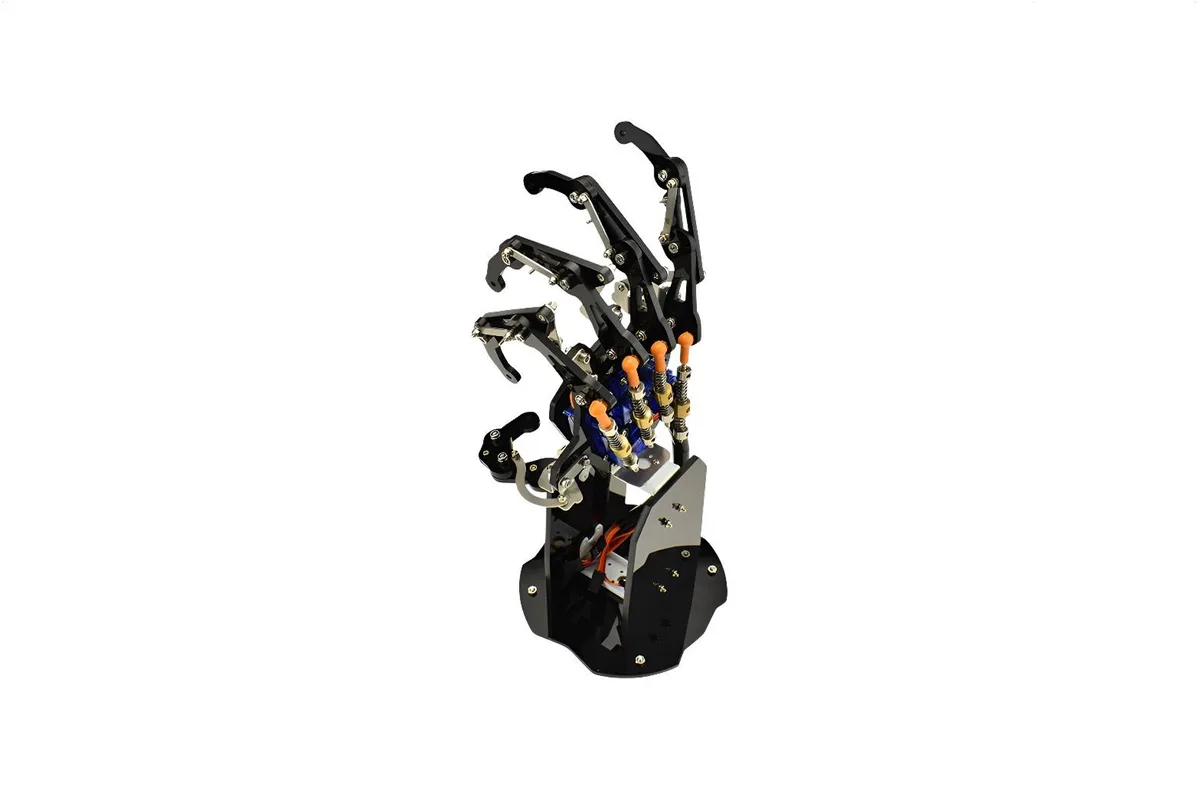
Five-finger bionic robot hand (right)
Limited record: this part has neither specifications nor a datasheet in the catalog yet. It is shown for reference and is not indexed.
Five-finger bionic robot hand (right)
Educational STEM Coding & Sensor Starter Packs
Right bionic robot hand with five articulated fingers driven by metal micro servos, intended for robotics demonstrations and educational projects.
Bionic robot hand DFRobot ROB0143. right bionic robot hand with five articulated fingers, a gripping mechanism for teaching and prototyping.
Structure and actuation. The hand is built from lightweight acrylic and integrates five micro metal servos. Each finger is controlled independently, enabling gesture reproduction and object grasping. Hand height: 330 mm; complete kit weight: 916 g.
Servo characteristics. Each servo measures 23 × 12.2 × 29 mm and weighs 14 g. Torque of 2.4 kg·cm at 4.8 V and 2.8 kg·cm at 6 V; speed of 0.11 s/60° at 4.8 V and 0.09 s/60° at 6 V; control signal of 1.0 ms to 2.0 ms (45 to 135°). Payload of 500 g.
Mechanical damping. Each finger includes a spring damping mechanism that absorbs stress during gripping or impacts, reducing loads on servo gears and joints.
Power. Operating voltage of 4.8 to 6 V; operating current of 2 A; recommended power supply 5 V @ 2 A. Operating temperature range of 0 to 55 °C.
Control and integration. The hand is Arduino compatible for motion programming, with individual finger control. It can also be driven by the Veyron 24-channel servo controller, which allows PC-based programming, wireless operation and real-time debugging.
Typical uses. Robotics demonstrations, teaching multi-axis control and servo synchronization, manipulation prototypes and laboratory robotics experiments.
Caution. Non-standard servo operation may damage the servos, even with the integrated damping. Available on quotation from Atlas Electronics.
No published question about this part yet. Questions are reviewed before publication.
Official documents and the technical data recorded for ROB0143. For a missing document or a specific revision, our experts send it to you.
Right bionic robot hand with five articulated fingers driven by metal micro servos, intended for robotics demonstrations and educational projects.
Similar parts to answer your needs. Compare the main characteristics. A recorded replacement is a documented relation; a similar product is a similarity only, never a compatibility claim.
Five-finger bionic robot hand (right)
5pcs 1.5V-6V Type Miniature DC Motors

Multicolored Dupont Wire Kit for Arduino® (120pcs)

USB3.0 HUB Extender Compatible with Ros Robot/Car Raspberry Pi Jetson Series Boards

Describe your application and constraints in a request.
What is recorded about the regulatory status and the life of this part.
No compliance statement is recorded for this part. Ask the supplier for the RoHS and REACH declarations and, for a radio product, the EU declaration of conformity.
| Current status | Status not stated |
| Key dates | Not recorded |
| Manufacturer part number | ROB0143 |
| Manufacturer | DFRobot |
Educational STEM Coding & Sensor Starter Packs
5 V Power Booster and Charger Module for Single-Cell Lithium Battery · Ref. : DFR0446
Price on request
Educational STEM Coding & Sensor Starter Packs
30 kg·cm magnetic encoder bus servo 360° · Ref. : 21100250
Price on request
Educational STEM Coding & Sensor Starter Packs
ROS2 Omnidirectional Mecanum Wheel Mobile Robot · Ref. : 3000200901
Price on request
Educational STEM Coding & Sensor Starter Packs
ESP32 robot chassis expansion shield
Price on request
No advertising or analytics cookies. A single, strictly necessary cookie is set only if you sign in to your account. Your quote basket and comparison stay in your browser. Details


