U229
9-DoF IMU Unit with BMI270 and BMM350
- Accelerometer Range
- ±2 g / ±4 g / ±8 g / ±16 g
- Gyroscope Range
- ±125 / ±250 / ±500 / ±1000 / ±2000 °/s
- Accelerometer Accuracy
- ±20 mg (approx. ±0.02 g)
- Gyroscope Accuracy
- ±0.5 °/s
9-DoF IMU Unit with BMI270 and BMM350
Maker, Prototyping, Open-Hardware & Developer Boards
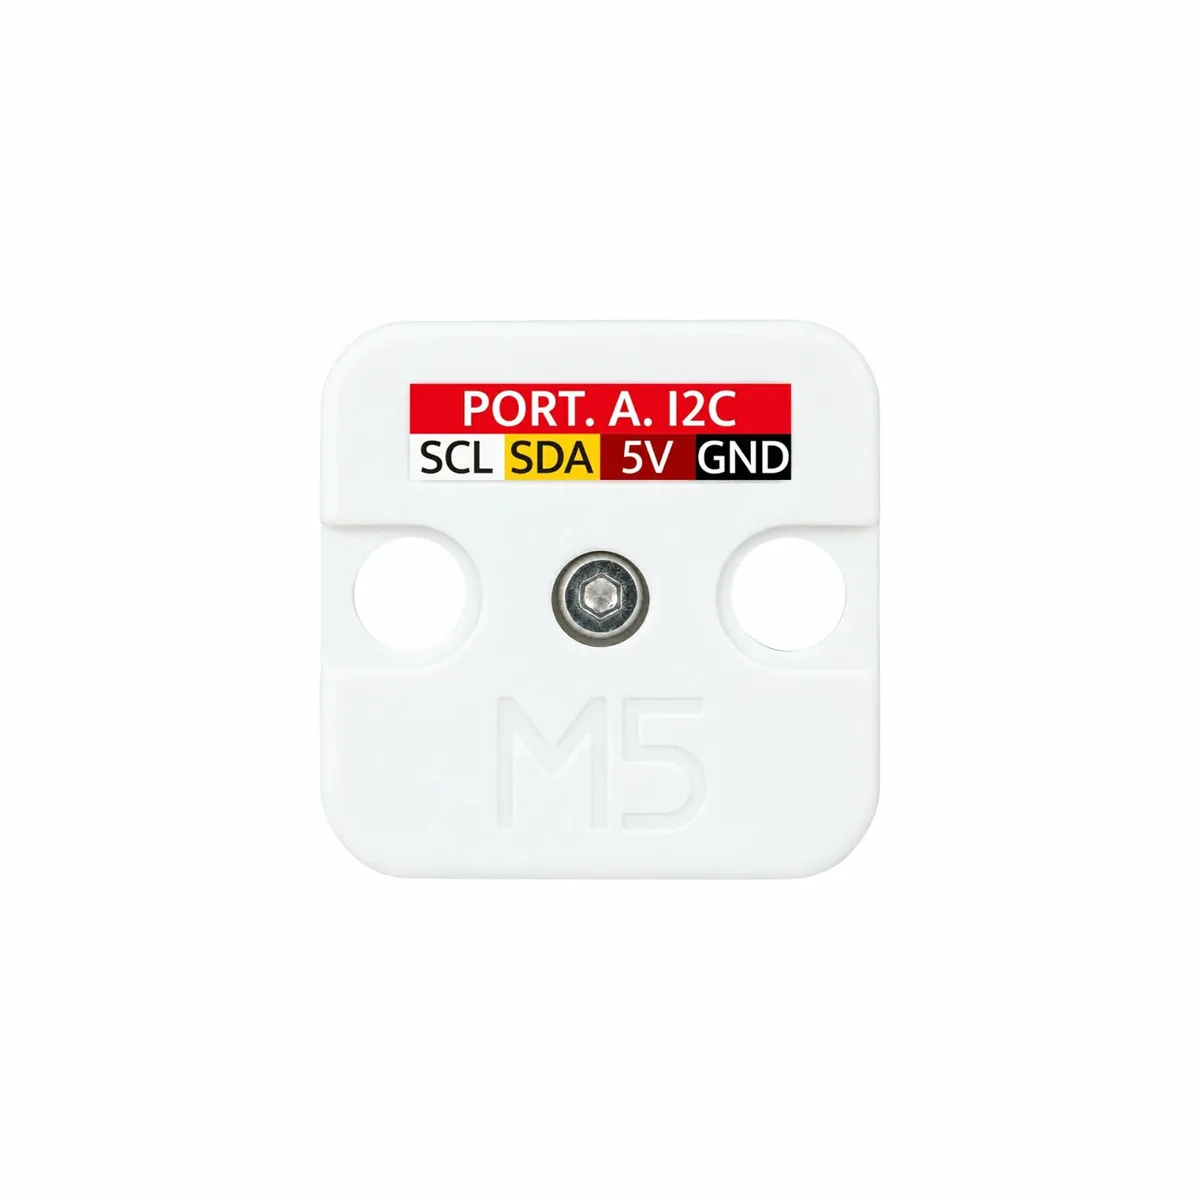
M5Stack U229 9-DoF IMU unit combining a six-axis BMI270 inertial sensor and a three-axis BMM350 magnetometer, designed for attitude and heading sensing.
Overview. The M5Stack U229 is a nine-axis inertial measurement unit (Unit DoF9) combining a six-axis BMI270 inertial sensor and a three-axis BMM350 magnetometer, over an I2C interface.
Main characteristics. The BMI270 integrates a 16-bit 3-axis accelerometer with ranges of ±2 g, ±4 g, ±8 g or ±16 g and an accuracy of approx. ±20 mg, and a 16-bit 3-axis gyroscope with ranges of ±125 to ±2000 °/s and an accuracy of ±0.5 °/s. The BMM350 measures the magnetic field on three axes, with a range of ±2000 μT per axis and a resolution of approx. 0.1 μT.
Interfaces and connectivity. Data is transmitted over I2C. The BMI270 address is 0x68 or 0x69, selectable by an onboard switch, and the BMM350 address is 0x14. A 5 cm HY2.0-4P Grove cable is included.
Typical uses. Robot attitude sensing, heading detection, electronic compass, motion tracking, navigation assistance and gimbal control.
Dimensions and weight. Product size 24.0 x 24.0 x 8.0 mm, weight 3.1 g.
Integration. On-chip motion detection and real-time acquisition of inertial, temperature and magnetic field data.
No published question about this part yet. Questions are reviewed before publication.
Every characteristic recorded for U229, with where it comes from. Use the filters to find one quickly.
| Characteristic | Value |
|---|---|
| Accelerometer | 16-bit 3-axis accelerometer |
| Accelerometer Accuracy | ±20 mg (approx. ±0.02 g) |
| Accelerometer Range | ±2 g / ±4 g / ±8 g / ±16 g |
| Barometric Pressure Sensor | Unit DoF6: ❌; Unit DoF9: ❌; Unit DoF10: SPA06-003; Unit BMM350: ❌ |
| BMI270 I2C Address | I2C @ 0x68 / 0x69 (switchable via onboard switch) |
| BMM350 I2C Address | I2C @ 0x14 |
| Geomagnetic Sensor IC | BMM350 |
| Gross weight | 6.6g |
| Gyroscope | 16-bit 3-axis gyroscope |
| Gyroscope Accuracy | ±0.5 °/s |
| Gyroscope Range | ±125 / ±250 / ±500 / ±1000 / ±2000 °/s |
| I2C Address | Unit DoF6: 0x68 / 0x69 (onboard switch); Unit DoF9: BMI270: 0x68 / 0x69 (onboard switch); BMM350: 0x14; Unit DoF10: BMI270: 0x68 / 0x69 (onboard switch); BMM350: 0x14; SPA06-003: 0x76; Unit BMM350: 0x14 |
| Inertial Sensor IC | BMI270 |
| Magnetic Field Range | X/Y/Z axes: ±2000 μT (typical on each axis) |
| Magnetic Field Resolution | approx. 0.1 μT |
| Magnetometer | BMM350 three-axis magnetometer |
| Main Functions | Unit DoF6: Acceleration, angular velocity, and temperature acquisition; on-chip motion detection; Unit DoF9: Acceleration, angular velocity, temperature, and three-axis magnetic field acquisition; on-chip motion detection; Unit DoF10: Acceleration, angular velocity, temperature, three-axis magnetic field, and pressure acquisition; on-chip motion detection; Unit BMM350: Three-axis magnetic field acquisition; heading output after calibration |
| Package Size | 138.0 x 93.0 x 7.0mm |
| Product Size | 24.0 x 24.0 x 8.0mm |
| Product Weight | 3.1g |
| Sensor Combination | Unit DoF6: BMI270; Unit DoF9: BMI270 + BMM350; Unit DoF10: BMI270 + BMM350 + SPA06-003; Unit BMM350: BMM350 |
| Sensor Type | Six-axis inertial and three-axis geomagnetic sensor |
No specification matches.
Last verification : 2026-11-02
Official documents and the technical data recorded for U229. For a missing document or a specific revision, our experts send it to you.
M5Stack U229 9-DoF IMU unit combining a six-axis BMI270 inertial sensor and a three-axis BMM350 magnetometer, designed for attitude and heading sensing.
| Parameter | Value |
|---|---|
| Accelerometer | 16-bit 3-axis accelerometer |
| Accelerometer Accuracy | ±20 mg (approx. ±0.02 g) |
| Accelerometer Range | ±2 g / ±4 g / ±8 g / ±16 g |
| Barometric Pressure Sensor | Unit DoF6: ❌; Unit DoF9: ❌; Unit DoF10: SPA06-003; Unit BMM350: ❌ |
| BMI270 I2C Address | I2C @ 0x68 / 0x69 (switchable via onboard switch) |
| BMM350 I2C Address | I2C @ 0x14 |
| Geomagnetic Sensor IC | BMM350 |
| Gross weight | 6.6g |
| Gyroscope | 16-bit 3-axis gyroscope |
| Gyroscope Accuracy | ±0.5 °/s |
| Gyroscope Range | ±125 / ±250 / ±500 / ±1000 / ±2000 °/s |
| I2C Address | Unit DoF6: 0x68 / 0x69 (onboard switch); Unit DoF9: BMI270: 0x68 / 0x69 (onboard switch); BMM350: 0x14; Unit DoF10: BMI270: 0x68 / 0x69 (onboard switch); BMM350: 0x14; SPA06-003: 0x76; Unit BMM350: 0x14 |
| Inertial Sensor IC | BMI270 |
| Magnetic Field Range | X/Y/Z axes: ±2000 μT (typical on each axis) |
| Magnetic Field Resolution | approx. 0.1 μT |
| Magnetometer | BMM350 three-axis magnetometer |
| Main Functions | Unit DoF6: Acceleration, angular velocity, and temperature acquisition; on-chip motion detection; Unit DoF9: Acceleration, angular velocity, temperature, and three-axis magnetic field acquisition; on-chip motion detection; Unit DoF10: Acceleration, angular velocity, temperature, three-axis magnetic field, and pressure acquisition; on-chip motion detection; Unit BMM350: Three-axis magnetic field acquisition; heading output after calibration |
| Package Size | 138.0 x 93.0 x 7.0mm |
| Product Size | 24.0 x 24.0 x 8.0mm |
| Product Weight | 3.1g |
| Sensor Combination | Unit DoF6: BMI270; Unit DoF9: BMI270 + BMM350; Unit DoF10: BMI270 + BMM350 + SPA06-003; Unit BMM350: BMM350 |
| Sensor Type | Six-axis inertial and three-axis geomagnetic sensor |
Answers to the questions that the recorded characteristics of U229 can answer. A question is not asked when nothing is recorded to answer it.
Yes — recorded under "BMI270 I2C Address": I2C @ 0x68 / 0x69 (switchable via onboard switch).
Similar parts to answer your needs. Compare the main characteristics. A recorded replacement is a documented relation; a similar product is a similarity only, never a compatibility claim.
9-DoF IMU Unit with BMI270 and BMM350
Sensor Adapter for Click, QWIIC and Grove Modules
RS485 Module 3PEAK TP8485E

4-20mA Module STMicroelectronics LM2902

Describe your application and constraints in a request.
What is recorded about the regulatory status and the life of this part.
No compliance statement is recorded for this part. Ask the supplier for the RoHS and REACH declarations and, for a radio product, the EU declaration of conformity.
| Current status | Status not stated |
| Key dates | Not recorded |
| Manufacturer part number | U229 |
| Manufacturer | M5Stack |
Maker, Prototyping, Open-Hardware & Developer Boards
M12 fisheye lens for camera module · Ref. : M12_FISHEYE
Price on request
Maker, Prototyping, Open-Hardware & Developer Boards
RK3568 System-on-Module with 1 TOPS NPU
Price on request
Maker, Prototyping, Open-Hardware & Developer Boards
Dual Gigabit Ethernet Carrier Board for Raspberry Pi Compute Module 4
Price on request
Maker, Prototyping, Open-Hardware & Developer Boards
RK3568 Android tablet mainboard with DTV tuner · Ref. : K3-3568
Price on request
No advertising or analytics cookies. A single, strictly necessary cookie is set only if you sign in to your account. Your quote basket and comparison stay in your browser. Details