
SEN0695
Compact 9DOF IMU Sensor with I2C, Accelerometer, Gyroscope and Magnetometer
- Measurement Range
- ±2000 µT
- Communication interface
- I²C
- Low Power Current
- 0.37 mA
- Operating Current
- 0.92 mA
Compact 9DOF IMU Sensor with I2C, Accelerometer, Gyroscope and Magnetometer
Educational STEM Coding & Sensor Starter Packs
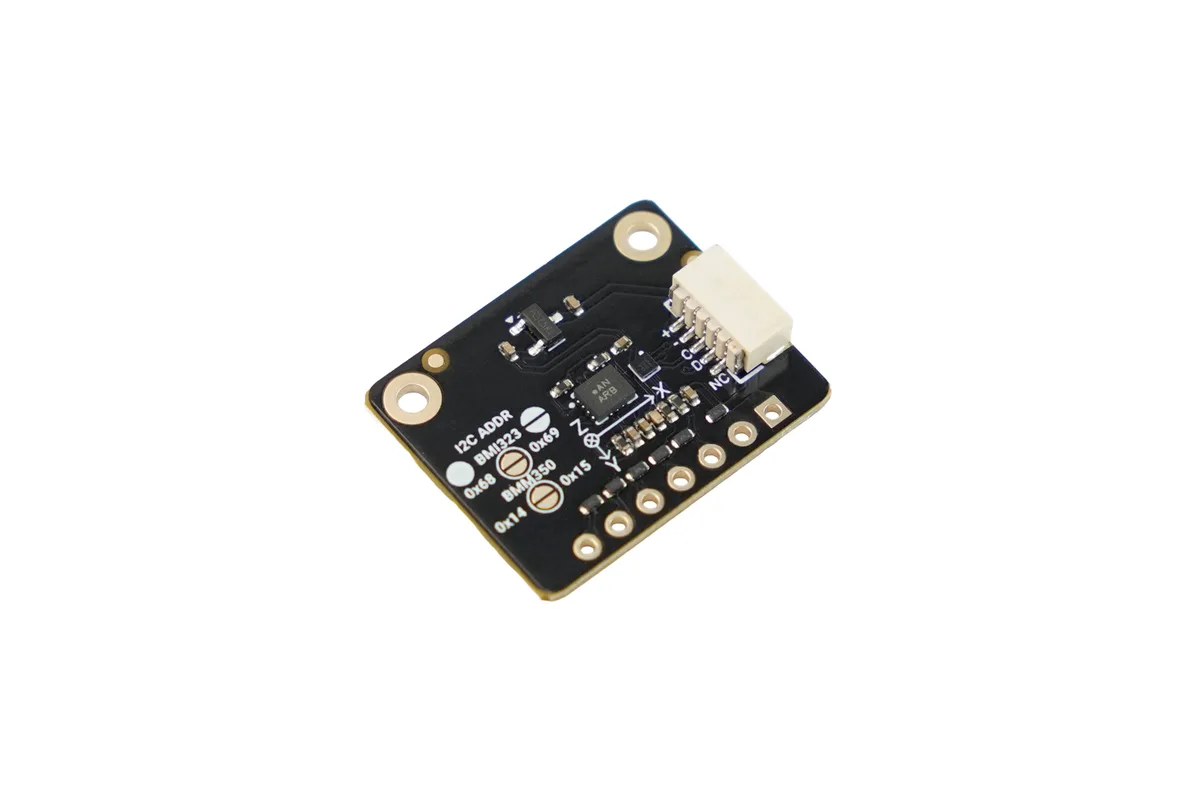
DFRobot SEN0695 9DOF IMU module combining accelerometer, gyroscope and magnetometer on a 24 × 19 mm board, communicating over I2C for motion and heading measurement.
DFRobot SEN0695. The SEN0695 Fermion is a compact 9DOF IMU sensor (accelerometer, gyroscope and magnetometer) on a 24 mm × 19 mm printed circuit board, designed to integrate motion and heading measurement into prototypes and embedded products.
Main characteristics. The accelerometer provides 16-bit resolution with ranges of ±2 g, ±4 g, ±8 g and ±16 g. The gyroscope, also 16-bit, covers angular rates of ±125, ±250, ±500, ±1000 and ±2000 °/s. The magnetometer measures a field of ±2000 µT with a resolution of approximately 0.1 µT.
Interfaces and connectivity. The module communicates over an I2C bus and provides an SH1.0-5P connector as well as 2.54 mm pin header holes. It has three programmable interrupt pins. The mounting holes have a diameter of 2 mm and a spacing of 19 mm.
Power and consumption. The module operates at 3.3 V. It draws 0.92 mA in operation and 0.37 mA in low-power mode. Operating modes include normal periodic measurement, triggered forced measurement and low-power sleep standby.
Typical uses. This sensor suits motion and orientation detection in embedded robots, wearable devices and electronic compass prototypes, as well as sensor evaluation.
No published question about this part yet. Questions are reviewed before publication.
Every characteristic recorded for SEN0695, with where it comes from. Use the filters to find one quickly.
| Characteristic | Value |
|---|---|
| Accelerometer ADC Resolution | 16-bit |
| Accelerometer Measurement Ranges | ±2 g, ±4 g, ±8 g, ±16 g |
| Accelerometer Sensitivity Error | ±0.5% |
| Accelerometer Zero-g Offset | ±50 mg |
| Communication interface | I²C |
| Connector Type | SH1.0-5P connector / 2.54 mm pin header holes |
| Fermion | Compact 9DOF IMU Sensor for Motion & Heading Integration (24×19 mm, I2C, Breakout) |
| Forced Mode Maximum Trigger Frequency | 200 Hz (avg=0 only) |
| Gyroscope ADC Resolution | 16-bit |
| Gyroscope Angular Rate Ranges | ±125, ±250, ±500, ±1000, ±2000 °/s |
| Gyroscope Sensitivity Error | ±3% (without self-calibration), ±0.7% (after self-calibration) |
| Gyroscope Zero-Rate Offset | ±1 °/s |
| Low Power Current | 0.37 mA |
| Magnetic Field Resolution | approx. 0.1 µT |
| Measurement Range | ±2000 µT |
| Mounting hole diameter | 2 mm |
| Mounting Hole Spacing | 19 mm |
| Normal Mode Output Data Rate | 400/200/100/50/25/12.5/6.25/3.125/1.5625 Hz, typical deviation ±2% |
| Offset Temperature Error | ±200 nT/K |
| Operating Current | 0.92 mA |
| Operating Modes | Normal periodic measurement, triggered forced measurement, low-power sleep standby |
| Operating Voltage | 3.3 V |
| PCB Size | 24 mm × 19 mm |
| Programmable Interrupt Pins | ×3 |
| Sensitivity Temperature Drift | ±0.010 %/K |
| X/Y-Axis Gain Error | ±1% (25 °C, after API compensation) |
| X/Y-Axis Output Noise | 190 nTrms |
| Z-Axis Gain Error | ±3% (25 °C, after API compensation) |
| Z-Axis Output Noise | 450 nTrms |
| Zero-Field Offset Drift | ±2 µT (-40 °C ~ +85 °C, after calibration) |
No specification matches.
Last verification : 2026-11-02
Official documents and the technical data recorded for SEN0695. For a missing document or a specific revision, our experts send it to you.
DFRobot SEN0695 9DOF IMU module combining accelerometer, gyroscope and magnetometer on a 24 × 19 mm board, communicating over I2C for motion and heading measurement.
| Parameter | Value |
|---|---|
| Accelerometer ADC Resolution | 16-bit |
| Accelerometer Measurement Ranges | ±2 g, ±4 g, ±8 g, ±16 g |
| Accelerometer Sensitivity Error | ±0.5% |
| Accelerometer Zero-g Offset | ±50 mg |
| Communication interface | I²C |
| Connector Type | SH1.0-5P connector / 2.54 mm pin header holes |
| Fermion | Compact 9DOF IMU Sensor for Motion & Heading Integration (24×19 mm, I2C, Breakout) |
| Forced Mode Maximum Trigger Frequency | 200 Hz (avg=0 only) |
| Gyroscope ADC Resolution | 16-bit |
| Gyroscope Angular Rate Ranges | ±125, ±250, ±500, ±1000, ±2000 °/s |
| Gyroscope Sensitivity Error | ±3% (without self-calibration), ±0.7% (after self-calibration) |
| Gyroscope Zero-Rate Offset | ±1 °/s |
| Low Power Current | 0.37 mA |
| Magnetic Field Resolution | approx. 0.1 µT |
| Measurement Range | ±2000 µT |
| Mounting hole diameter | 2 mm |
| Mounting Hole Spacing | 19 mm |
| Normal Mode Output Data Rate | 400/200/100/50/25/12.5/6.25/3.125/1.5625 Hz, typical deviation ±2% |
| Offset Temperature Error | ±200 nT/K |
| Operating Current | 0.92 mA |
| Operating Modes | Normal periodic measurement, triggered forced measurement, low-power sleep standby |
| Operating Voltage | 3.3 V |
| PCB Size | 24 mm × 19 mm |
| Programmable Interrupt Pins | ×3 |
| Sensitivity Temperature Drift | ±0.010 %/K |
| X/Y-Axis Gain Error | ±1% (25 °C, after API compensation) |
| X/Y-Axis Output Noise | 190 nTrms |
| Z-Axis Gain Error | ±3% (25 °C, after API compensation) |
| Z-Axis Output Noise | 450 nTrms |
| Zero-Field Offset Drift | ±2 µT (-40 °C ~ +85 °C, after calibration) |
Answers to the questions that the recorded characteristics of SEN0695 can answer. A question is not asked when nothing is recorded to answer it.
Yes — recorded under "Fermion": Compact 9DOF IMU Sensor for Motion & Heading Integration (24×19 mm, I2C, Breakout).
Similar parts to answer your needs. Compare the main characteristics. A recorded replacement is a documented relation; a similar product is a similarity only, never a compatibility claim.
Compact 9DOF IMU Sensor with I2C, Accelerometer, Gyroscope and Magnetometer
Fermion: Compact Low-Power 6DOF IMU Sensor for Embedded Motion Sensing (16x16mm, I2C, Breakout)

Fermion: Compact 10DOF IMU Sensor for Motion, Heading & Pressure Sensing (24×19mm, I2C, Breakout)

5pcs 1.5V-6V Type Miniature DC Motors

Describe your application and constraints in a request.
What is recorded about the regulatory status and the life of this part.
No compliance statement is recorded for this part. Ask the supplier for the RoHS and REACH declarations and, for a radio product, the EU declaration of conformity.
| Current status | Status not stated |
| Key dates | Not recorded |
| Manufacturer part number | SEN0695 |
| Manufacturer | DFRobot |
Educational STEM Coding & Sensor Starter Packs
5 V Power Booster and Charger Module for Single-Cell Lithium Battery · Ref. : DFR0446
Price on request
Educational STEM Coding & Sensor Starter Packs
30 kg·cm magnetic encoder bus servo 360° · Ref. : 21100250
Price on request
Educational STEM Coding & Sensor Starter Packs
ROS2 Omnidirectional Mecanum Wheel Mobile Robot · Ref. : 3000200901
Price on request
Educational STEM Coding & Sensor Starter Packs
ESP32 robot chassis expansion shield
Price on request
No advertising or analytics cookies. A single, strictly necessary cookie is set only if you sign in to your account. Your quote basket and comparison stay in your browser. Details


