SEN0411
Triple Axis I2C Accelerometer with Selectable ±6g/±12g/±24g Scales

- Operating Temperature
- -40℃~+85℃
- Interface
- Gravity-I2C
- Operating Current
- 10uA(low power mode)/0.3mA(Normal mode)
- Frequency
- 0.5Hz~1KHz
Triple Axis I2C Accelerometer with Selectable ±6g/±12g/±24g Scales
DFRobot Gravity Sensor & Actuator System
LIS331HH triple axis linear accelerometer with ultra-low power consumption, for acceleration measurement, free-fall detection and motion-activated functions.
Overview. The DFRobot SEN0411 is a LIS331HH triple axis linear accelerometer, a Gravity-format module measuring 27 × 27 mm, designed to measure accelerations with output data rates from 0.5 Hz to 1 kHz.
Main characteristics. Selectable scales of ±6g, ±12g and ±24g, with 16-bit data output. Current consumption is 10 µA in low power mode and 0.3 mA in normal mode.
Interfaces and connectivity. The module uses a Gravity-I2C interface, solderless, with a default I2C address of 0x19, changeable to 0x18 with a toggle switch. A Gravity-4P I2C/UART sensor connector is supplied.
Power and environment. The operating voltage ranges from 3.3 V to 5 V. The operating temperature range is -40 °C to +85 °C, and the sensor withstands a 10000 g high shock.
Typical uses. Free-fall detection, motion-activated functions, gaming and virtual reality input devices, navigation and robotics.
Integration. Direct connection on an I2C bus, mounting with holes of 3 mm inner diameter.
No published question about this part yet. Questions are reviewed before publication.
Every characteristic recorded for SEN0411, with where it comes from. Use the filters to find one quickly.
| Characteristic | Value |
|---|---|
| Frequency | 0.5Hz~1KHz |
| Gravity | I2C LIS331HH Triple Axis Accelerometer (±6g/±12g/±24g) |
| I2C Address | 0x19 (Default)/0x18 (Optional) |
| Interface | Gravity-I2C |
| Module size | 27*27mm/1.06*1.06” |
| Operating Current | 10uA(low power mode)/0.3mA(Normal mode) |
| Operating Temperature | -40℃~+85℃ |
| Operating Voltage | 3.3V~5V |
| Selectable Scale | ±6g/±12g/±24g |
| Selectable scales | ±6g/±12g/±24g |
No specification matches.
Last verification : 2026-11-02
Official documents and the technical data recorded for SEN0411. For a missing document or a specific revision, our experts send it to you.
LIS331HH triple axis linear accelerometer with ultra-low power consumption, for acceleration measurement, free-fall detection and motion-activated functions.
| Parameter | Value |
|---|---|
| Frequency | 0.5Hz~1KHz |
| Gravity | I2C LIS331HH Triple Axis Accelerometer (±6g/±12g/±24g) |
| I2C Address | 0x19 (Default)/0x18 (Optional) |
| Interface | Gravity-I2C |
| Module size | 27*27mm/1.06*1.06” |
| Operating Current | 10uA(low power mode)/0.3mA(Normal mode) |
| Operating Temperature | -40℃~+85℃ |
| Operating Voltage | 3.3V~5V |
| Selectable Scale | ±6g/±12g/±24g |
| Selectable scales | ±6g/±12g/±24g |
Points to check before using SEN0411 in a design. They are derived from the recorded characteristics, not from the manufacturer's application circuits.
| Operating Current | 10uA(low power mode)/0.3mA(Normal mode) |
| Operating Voltage | 3.3V~5V |
Check the exact pin assignment and the application circuit in the datasheet, or ask our experts.
Answers to the questions that the recorded characteristics of SEN0411 can answer. A question is not asked when nothing is recorded to answer it.
Yes — recorded under "Gravity": I2C LIS331HH Triple Axis Accelerometer (±6g/±12g/±24g).
-40℃~+85℃ (source: Operating Temperature).
Similar parts to answer your needs. Compare the main characteristics. A recorded replacement is a documented relation; a similar product is a similarity only, never a compatibility claim.
Triple Axis I2C Accelerometer with Selectable ±6g/±12g/±24g Scales
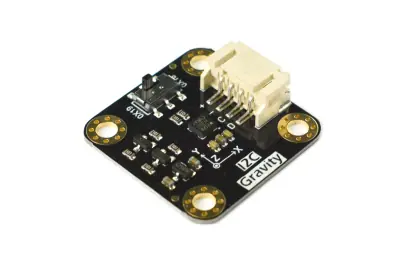
Gravity: I2C H3LIS200DL Triple Axis Accelerometer (±100g/±200g)
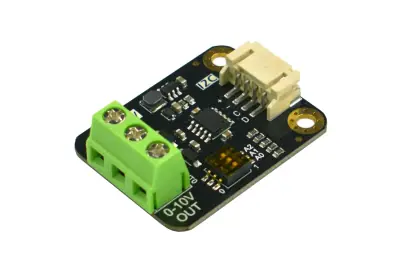
Gravity: 2-Channel I2C DAC Module (0-10V)
Gravity: I2C LIS2DW12 Triple Axis Accelerometer Sensor (±2g/±4g/±8g/±16g)

Describe your application and constraints in a request.
What is recorded about the regulatory status and the life of this part.
No compliance statement is recorded for this part. Ask the supplier for the RoHS and REACH declarations and, for a radio product, the EU declaration of conformity.
| Current status | Status not stated |
| Key dates | Not recorded |
| Manufacturer part number | SEN0411 |
| Manufacturer | DFRobot |
DFRobot Gravity Sensor & Actuator System
Dual bipolar stepper motor shield for Arduino with DRV8825 driver · Ref. : DRI0023
Price on request
DFRobot Gravity Sensor & Actuator System
Analog Piezo Disk Vibration Sensor · Ref. : DFR0052
Price on request
DFRobot Gravity Sensor & Actuator System
2x2A dual-channel motor shield for Arduino
Price on request
DFRobot Gravity Sensor & Actuator System
Expansion board for Raspberry Pi Pico and Pico 2 · Ref. : DFR0848
Price on request
No advertising or analytics cookies. A single, strictly necessary cookie is set only if you sign in to your account. Your quote basket and comparison stay in your browser. Details