SEN0694
9DOF IMU Sensor with Accelerometer, Gyroscope and Magnetometer
- Measurement Range
- ±2000 µT
- Communication interface
- I²C / UART
- Operating Current
- 3.42 mA
- Forced Mode Maximum Trigger Frequency
- 200 Hz
9DOF IMU Sensor with Accelerometer, Gyroscope and Magnetometer
DFRobot Gravity Sensor & Actuator System
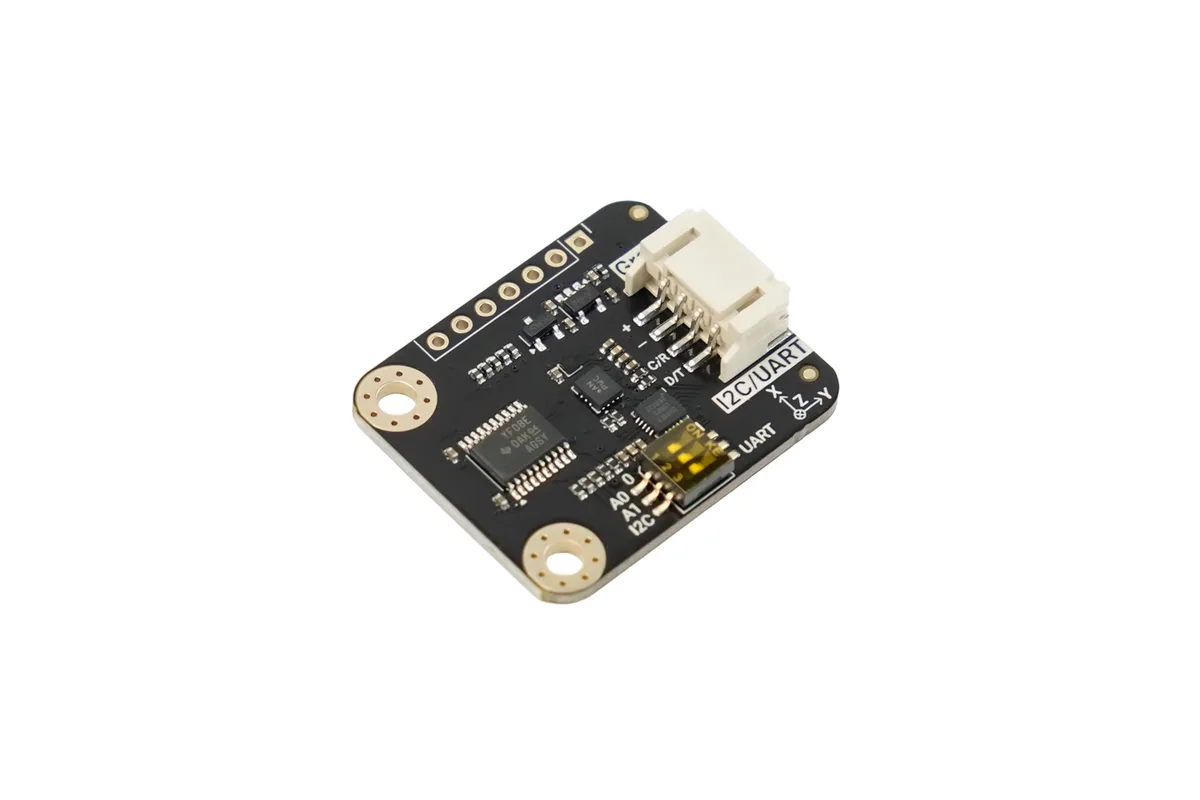
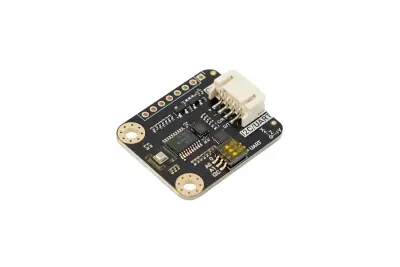
DFRobot 9DOF IMU module combining BMI323 accelerometer and gyroscope with BMM350 magnetometer for motion, heading and orientation sensing over I2C or UART.
Overview. The DFRobot Gravity BMI323+BMM350 (reference SEN0694) is a 9DOF IMU sensor combining a Bosch BMI323 3-axis accelerometer and gyroscope with a Bosch BMM350 3-axis magnetometer. It provides acceleration, angular velocity and magnetic field data for motion and heading evaluation.
Main characteristics. 16-bit ADC resolution. The accelerometer covers ±2 g, ±4 g, ±8 g and ±16 g, the gyroscope ±125, ±250, ±500, ±1000 and ±2000 °/s. The magnetometer measures up to ±2000 µT with approximately 0.1 µT resolution. Normal mode output data rates from 400 to 1.5625 Hz, and forced mode triggering up to 200 Hz. Output noise of 190 nTrms on the X/Y axes and 450 nTrms on the Z axis.
Interfaces and connectivity. I²C or UART communication, with I²C addresses 0x4A (default), 0x4B, 0x4C and 0x4D. PH2.0-4P connector with Gravity pinout and 2.54 mm pin header holes. Three programmable interrupt pins allow sensor events to signal the host system.
Power and environment. Operating voltage DC 3.3–5 V, operating current 3.42 mA. Operating modes: normal periodic measurement, triggered forced measurement and low-power sleep standby. Offset temperature error of ±200 nT/K and zero-field offset drift of ±2 µT from -40 °C to +85 °C after calibration.
Typical uses. Electronic compass projects, robot direction feedback and orientation of wearable objects, with rapid prototyping on Arduino, ESP32 and Raspberry Pi using the DFRobot library.
Dimensions and mounting. PCB size 32 mm × 27 mm, mounting holes of 3 mm diameter spaced 20 mm apart.
No published question about this part yet. Questions are reviewed before publication.
Every characteristic recorded for SEN0694, with where it comes from. Use the filters to find one quickly.
| Characteristic | Value |
|---|---|
| ADC Resolution | 16-bit |
| Angular Rate Ranges | ±125, ±250, ±500, ±1000, ±2000 °/s |
| Communication interface | I²C / UART |
| Connector Type | PH2.0-4P (Gravity pinout) / 2.54 mm pin header holes |
| Forced Mode Maximum Trigger Frequency | 200 Hz |
| Gravity | 9DOF IMU Sensor for Motion, Heading & Orientation (I2C / UART, Plug & Play) |
| I²C Addresses | 0x4A (default) / 0x4B / 0x4C / 0x4D |
| Magnetic Field Resolution | approx. 0.1 µT |
| Measurement Range | ±2000 µT |
| Measurement Ranges | ±2 g, ±4 g, ±8 g, ±16 g |
| Mounting hole diameter | 3 mm |
| Mounting Hole Spacing | 20 mm |
| Normal Mode Output Data Rate | 400/200/100/50/25/12.5/6.25/3.125/1.5625 Hz, typical deviation ±2% |
| Offset Temperature Error | ±200 nT/K |
| Operating Current | 3.42 mA |
| Operating Modes | Normal periodic measurement, triggered forced measurement, low-power sleep standby |
| Operating Voltage | DC 3.3–5 V |
| PCB Size | 32 mm × 27 mm |
| Programmable Interrupt Pins | ×3 |
| Sensitivity Error | ±0.5% |
| Sensitivity Temperature Drift | ±0.010 %/K |
| X/Y-Axis Gain Error | ±1% (25 °C, after compensation) |
| X/Y-Axis Output Noise | 190 nTrms |
| Z-Axis Gain Error | ±3% (25 °C, after compensation) |
| Z-Axis Output Noise | 450 nTrms |
| Zero-Field Offset Drift | ±2 µT (-40 °C ~ +85 °C, after calibration) |
| Zero-g Offset | ±50 mg |
| Zero-Rate Offset | ±1 °/s |
No specification matches.
Last verification : 2026-11-02
Official documents and the technical data recorded for SEN0694. For a missing document or a specific revision, our experts send it to you.
DFRobot 9DOF IMU module combining BMI323 accelerometer and gyroscope with BMM350 magnetometer for motion, heading and orientation sensing over I2C or UART.
| Parameter | Value |
|---|---|
| ADC Resolution | 16-bit |
| Angular Rate Ranges | ±125, ±250, ±500, ±1000, ±2000 °/s |
| Communication interface | I²C / UART |
| Connector Type | PH2.0-4P (Gravity pinout) / 2.54 mm pin header holes |
| Forced Mode Maximum Trigger Frequency | 200 Hz |
| Gravity | 9DOF IMU Sensor for Motion, Heading & Orientation (I2C / UART, Plug & Play) |
| I²C Addresses | 0x4A (default) / 0x4B / 0x4C / 0x4D |
| Magnetic Field Resolution | approx. 0.1 µT |
| Measurement Range | ±2000 µT |
| Measurement Ranges | ±2 g, ±4 g, ±8 g, ±16 g |
| Mounting hole diameter | 3 mm |
| Mounting Hole Spacing | 20 mm |
| Normal Mode Output Data Rate | 400/200/100/50/25/12.5/6.25/3.125/1.5625 Hz, typical deviation ±2% |
| Offset Temperature Error | ±200 nT/K |
| Operating Current | 3.42 mA |
| Operating Modes | Normal periodic measurement, triggered forced measurement, low-power sleep standby |
| Operating Voltage | DC 3.3–5 V |
| PCB Size | 32 mm × 27 mm |
| Programmable Interrupt Pins | ×3 |
| Sensitivity Error | ±0.5% |
| Sensitivity Temperature Drift | ±0.010 %/K |
| X/Y-Axis Gain Error | ±1% (25 °C, after compensation) |
| X/Y-Axis Output Noise | 190 nTrms |
| Z-Axis Gain Error | ±3% (25 °C, after compensation) |
| Z-Axis Output Noise | 450 nTrms |
| Zero-Field Offset Drift | ±2 µT (-40 °C ~ +85 °C, after calibration) |
| Zero-g Offset | ±50 mg |
| Zero-Rate Offset | ±1 °/s |
Answers to the questions that the recorded characteristics of SEN0694 can answer. A question is not asked when nothing is recorded to answer it.
Yes — recorded under "Gravity": 9DOF IMU Sensor for Motion, Heading & Orientation (I2C / UART, Plug & Play).
Similar parts to answer your needs. Compare the main characteristics. A recorded replacement is a documented relation; a similar product is a similarity only, never a compatibility claim.
9DOF IMU Sensor with Accelerometer, Gyroscope and Magnetometer
Gravity: 6DOF IMU Sensor for Motion & Gesture Detection (I2C / UART, Plug & Play)
Gravity: 10DOF IMU Sensor for Motion, Heading & Altitude Changes (I2C / UART, Plug & Play)
Gravity: 1602 LCD Keypad Shield For Arduino

Describe your application and constraints in a request.
What is recorded about the regulatory status and the life of this part.
No compliance statement is recorded for this part. Ask the supplier for the RoHS and REACH declarations and, for a radio product, the EU declaration of conformity.
| Current status | Status not stated |
| Key dates | Not recorded |
| Manufacturer part number | SEN0694 |
| Manufacturer | DFRobot |
DFRobot Gravity Sensor & Actuator System
Dual bipolar stepper motor shield for Arduino with DRV8825 driver · Ref. : DRI0023
Price on request
DFRobot Gravity Sensor & Actuator System
Analog Piezo Disk Vibration Sensor · Ref. : DFR0052
Price on request
DFRobot Gravity Sensor & Actuator System
2x2A dual-channel motor shield for Arduino
Price on request
DFRobot Gravity Sensor & Actuator System
Expansion board for Raspberry Pi Pico and Pico 2 · Ref. : DFR0848
Price on request
No advertising or analytics cookies. A single, strictly necessary cookie is set only if you sign in to your account. Your quote basket and comparison stay in your browser. Details